Measure. Adjust. Fill.
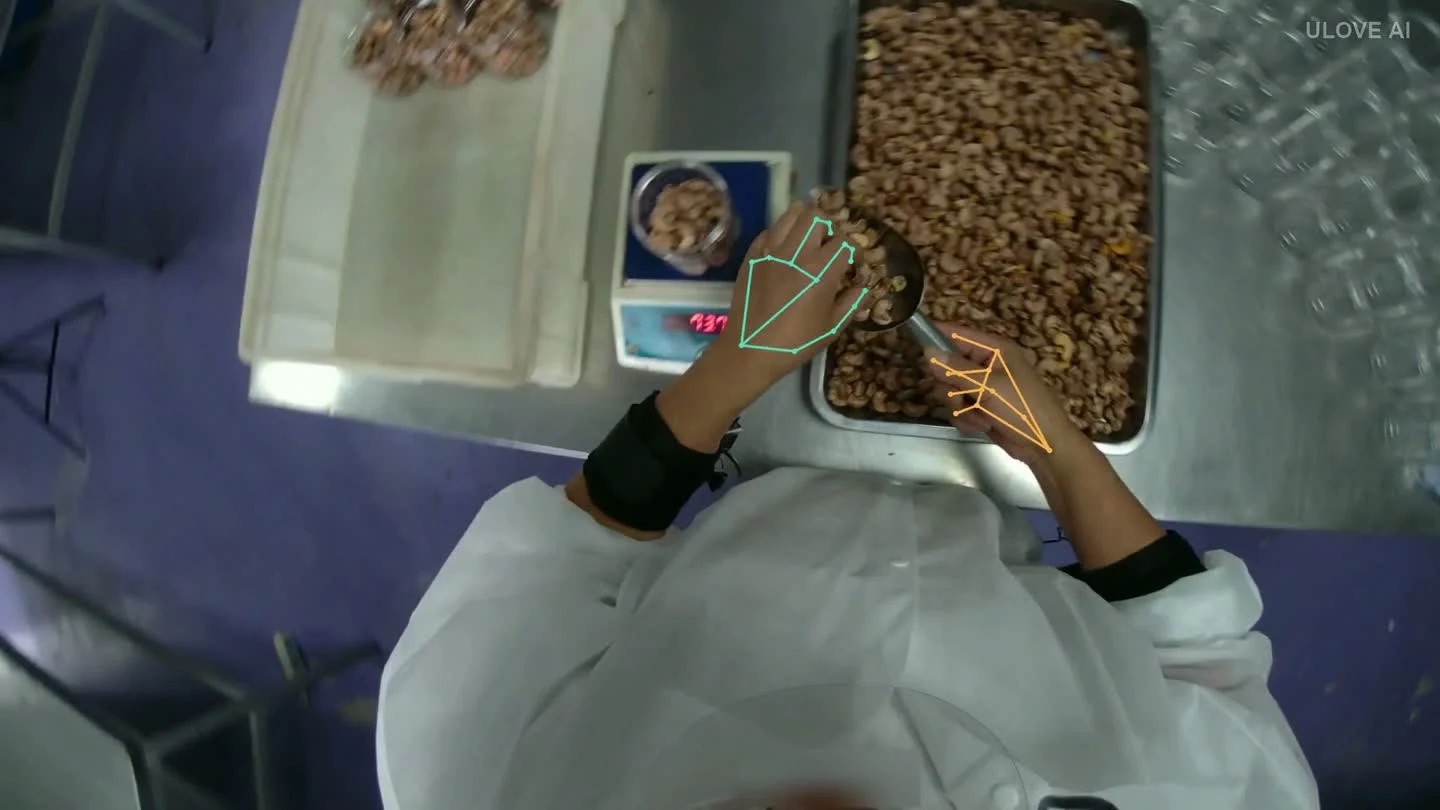
Object handling around a scoop, scale and container.
Inspect labels ↗Multi-view video and structured annotations from real industrial work. For robotics teams evaluating how people handle objects, complete tasks and recover from interruptions.
FIRST CAPTURE SCENARIO / FOOD HANDLING & PACKAGING
Explore our current evaluation sample: three selected operations, six camera views and annotations you can inspect.
View fields & sample specification ↗Annotated overview · 58 seconds · Face-blurred, ULOVE AI watermarked preview
Object handling around a scoop, scale and container.
Inspect labels ↗Container handling at a sealing machine.
Inspect labels ↗A container is retrieved from the floor and returned to a tray.
Inspect labels ↗Three independent operation excerpts. The recovery example shows floor retrieval and return; the initial drop is outside the clip. See the data specification for scope.
Capture context, label visible actions, and keep every selected frame connected to its source. Review the outputs before defining your next collection.
Head-mounted, wrist-mounted and external camera views document the same working environment.
Selected operations are segmented into labeled phases, with recovery behavior described where observed.
Image-space hand estimates with point provenance and visibility-dependent availability.
JSON and CSV annotations, source-frame mappings, integrity checks and an offline review interface.
Bring your target task and required fields. Together, we can define a pilot, review the data against your criteria, and scope a larger collection.
CURRENT EVALUATION DELIVERY
ULoveAI connects industrial capture scenarios in China with robotics and embodied AI teams, through a business contact in California.
Our current focus is human manipulation in food handling and packaging. Explore the sample, then define a pilot around your task and acceptance criteria.
Meet ULoveAI ↗Evaluating the sample or planning a collection? Share your requirements so we can identify a useful starting point.
yvonne@uloveai.us ↗US business contact · Pacific Time
Sample access and dataset licensing are discussed separately.